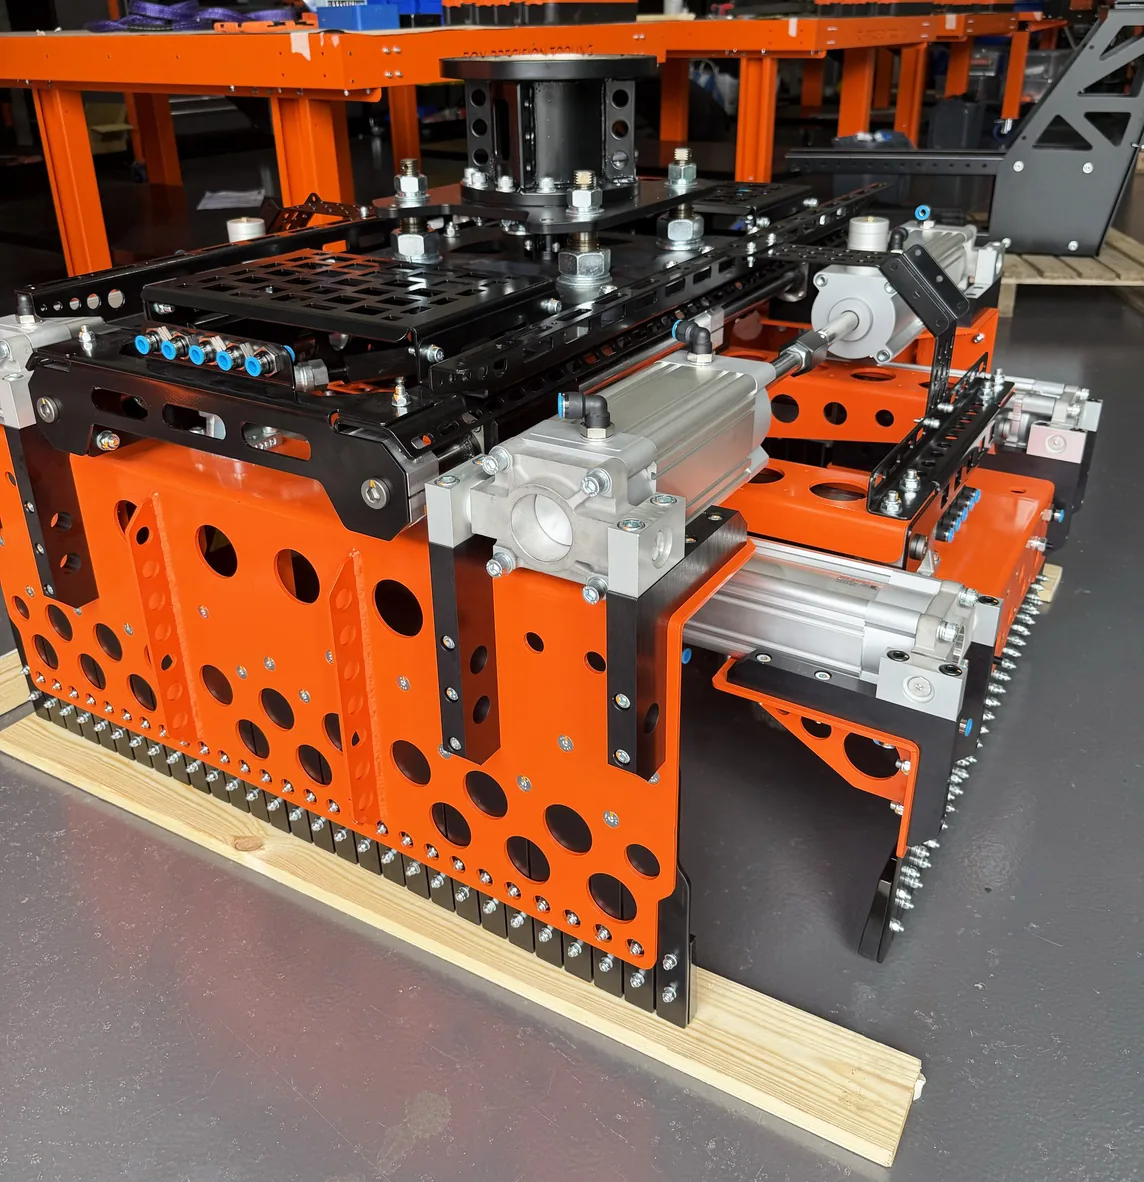
One tool, two independent pick axes.
Fired bricks need air moving through the stack for an even burn, so alternate courses can't sit the same way twice.
Firing bricks evenly means the stack can't be uniform
A leading UK brick manufacturer came to us with a problem that starts with physics rather than robotics. Fired bricks need air moving through the stack for an even burn, so alternate courses need to sit differently - some full, some offset - to open the channels that let heat and air pass through the pack on its way into the kiln. On most lines, picking two different layer patterns means two grippers, and often two robots, bolted into an already tight production cell.
The Dual Parallel Gripper: one mount, two pick systems
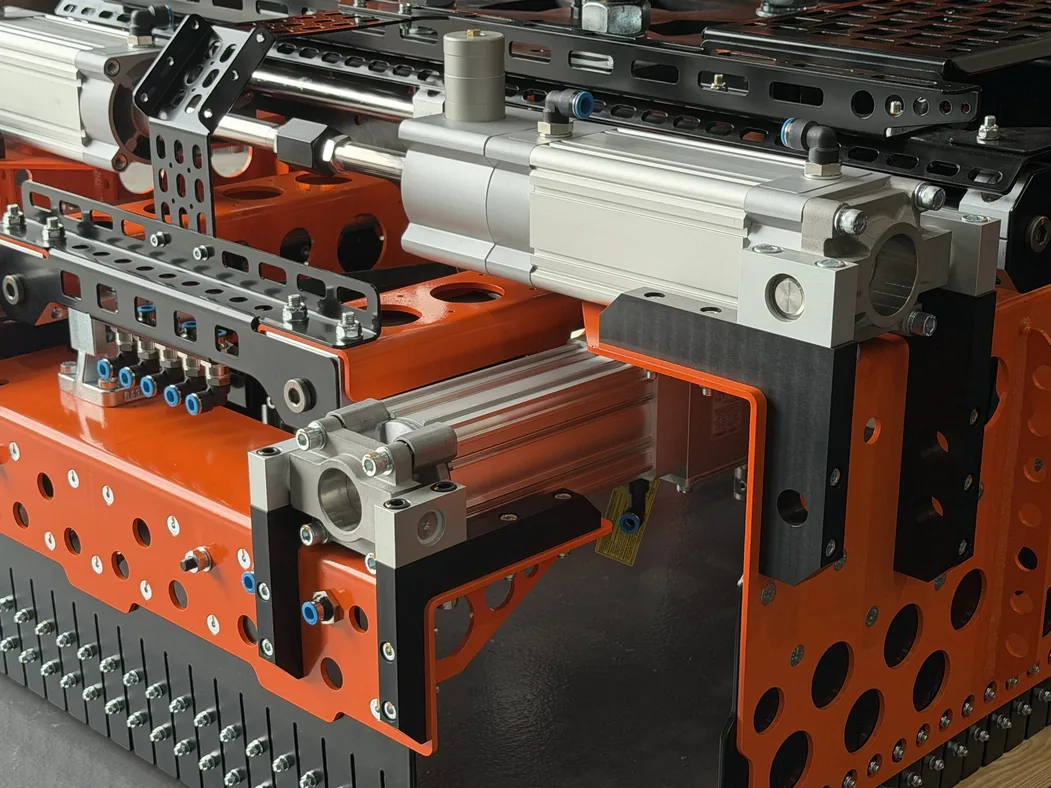
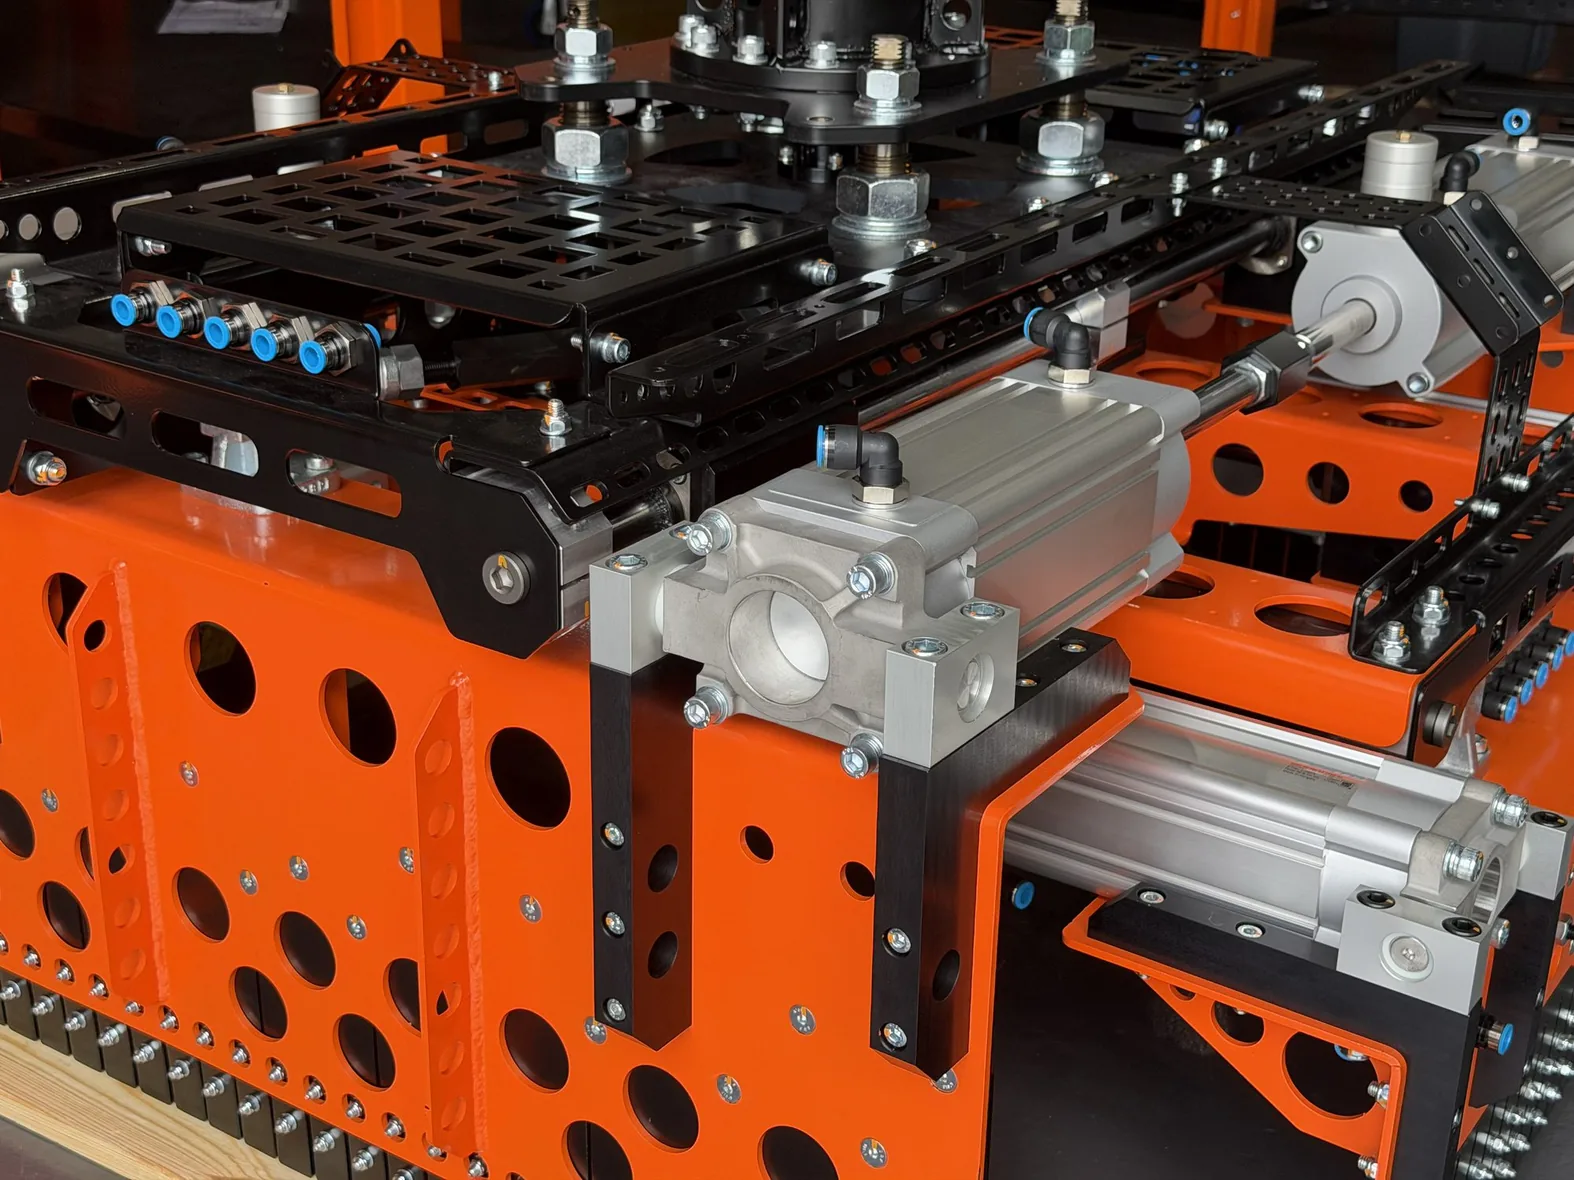
We took on the full design and build in house: one tool carrying two independently actuated pick systems on a single robot mount. The Main Axis Pick handles the full brick layer, closing across the complete course in one motion. The Support Axis Pick handles the fork layer, the offset pattern that opens the air gaps through the stack - each running its own pneumatic cylinders and stroke range, so the robot changes pattern without changing tools or stopping the line.